Autonomous Quadruped Challenge
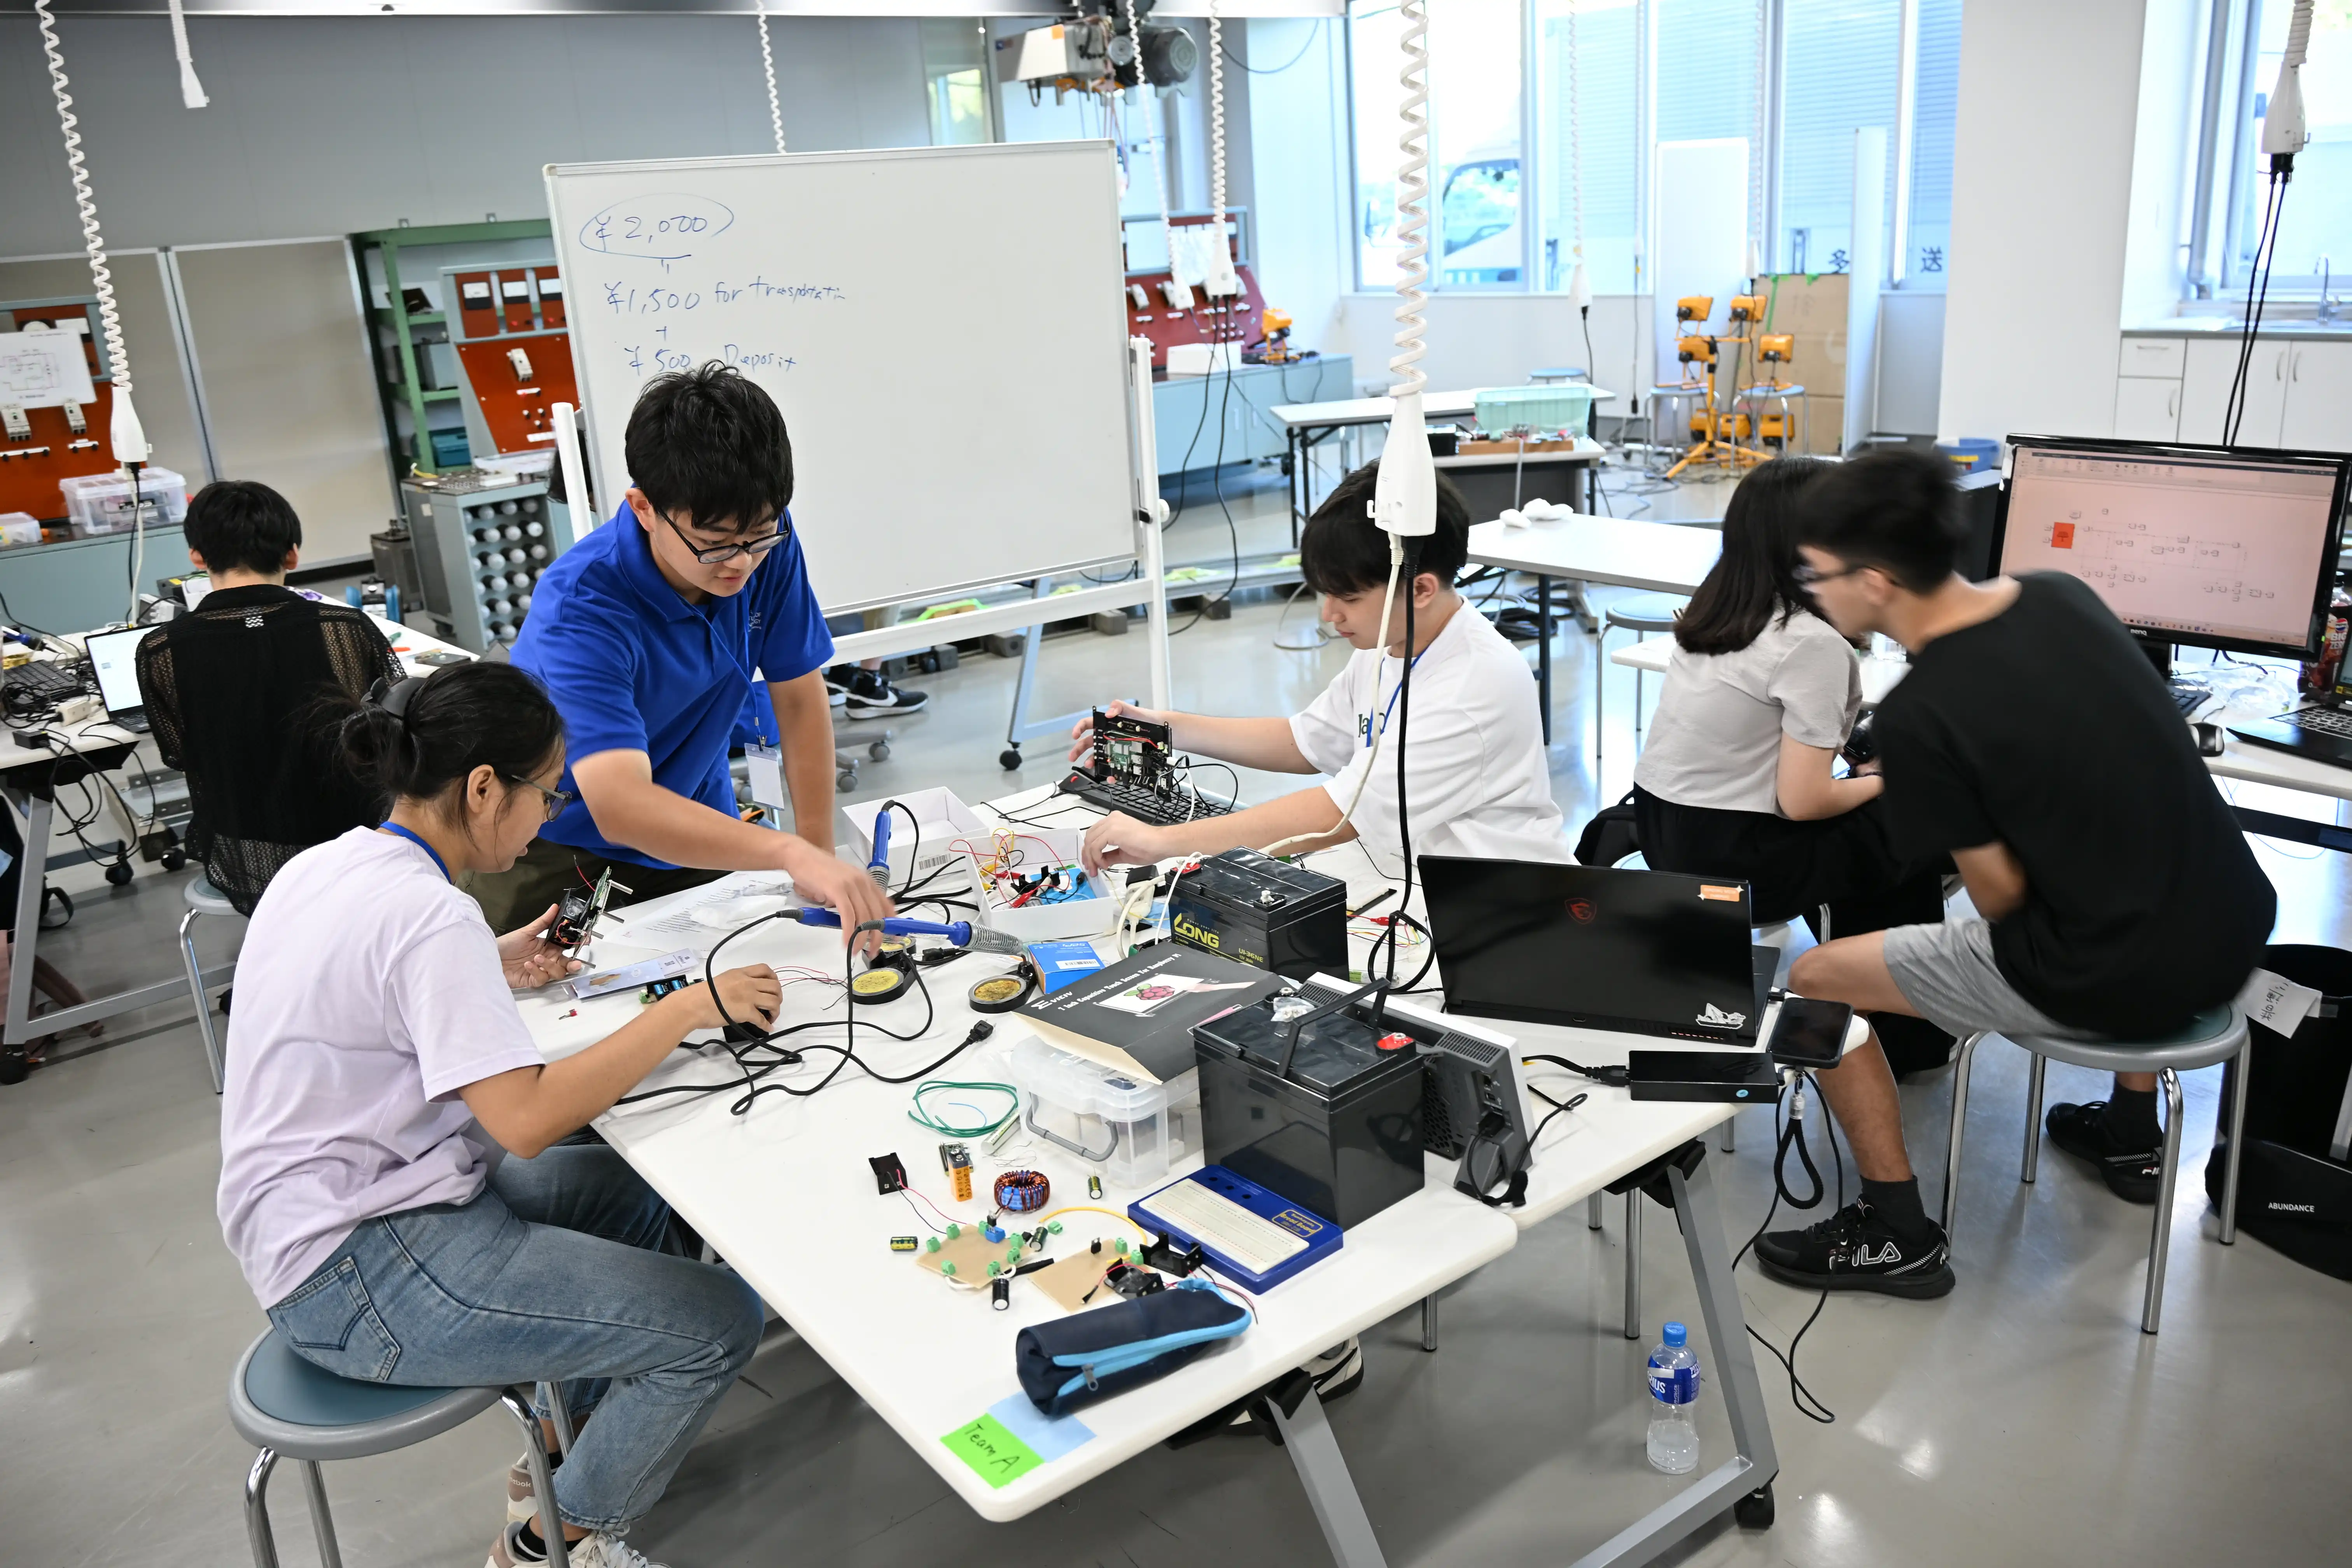
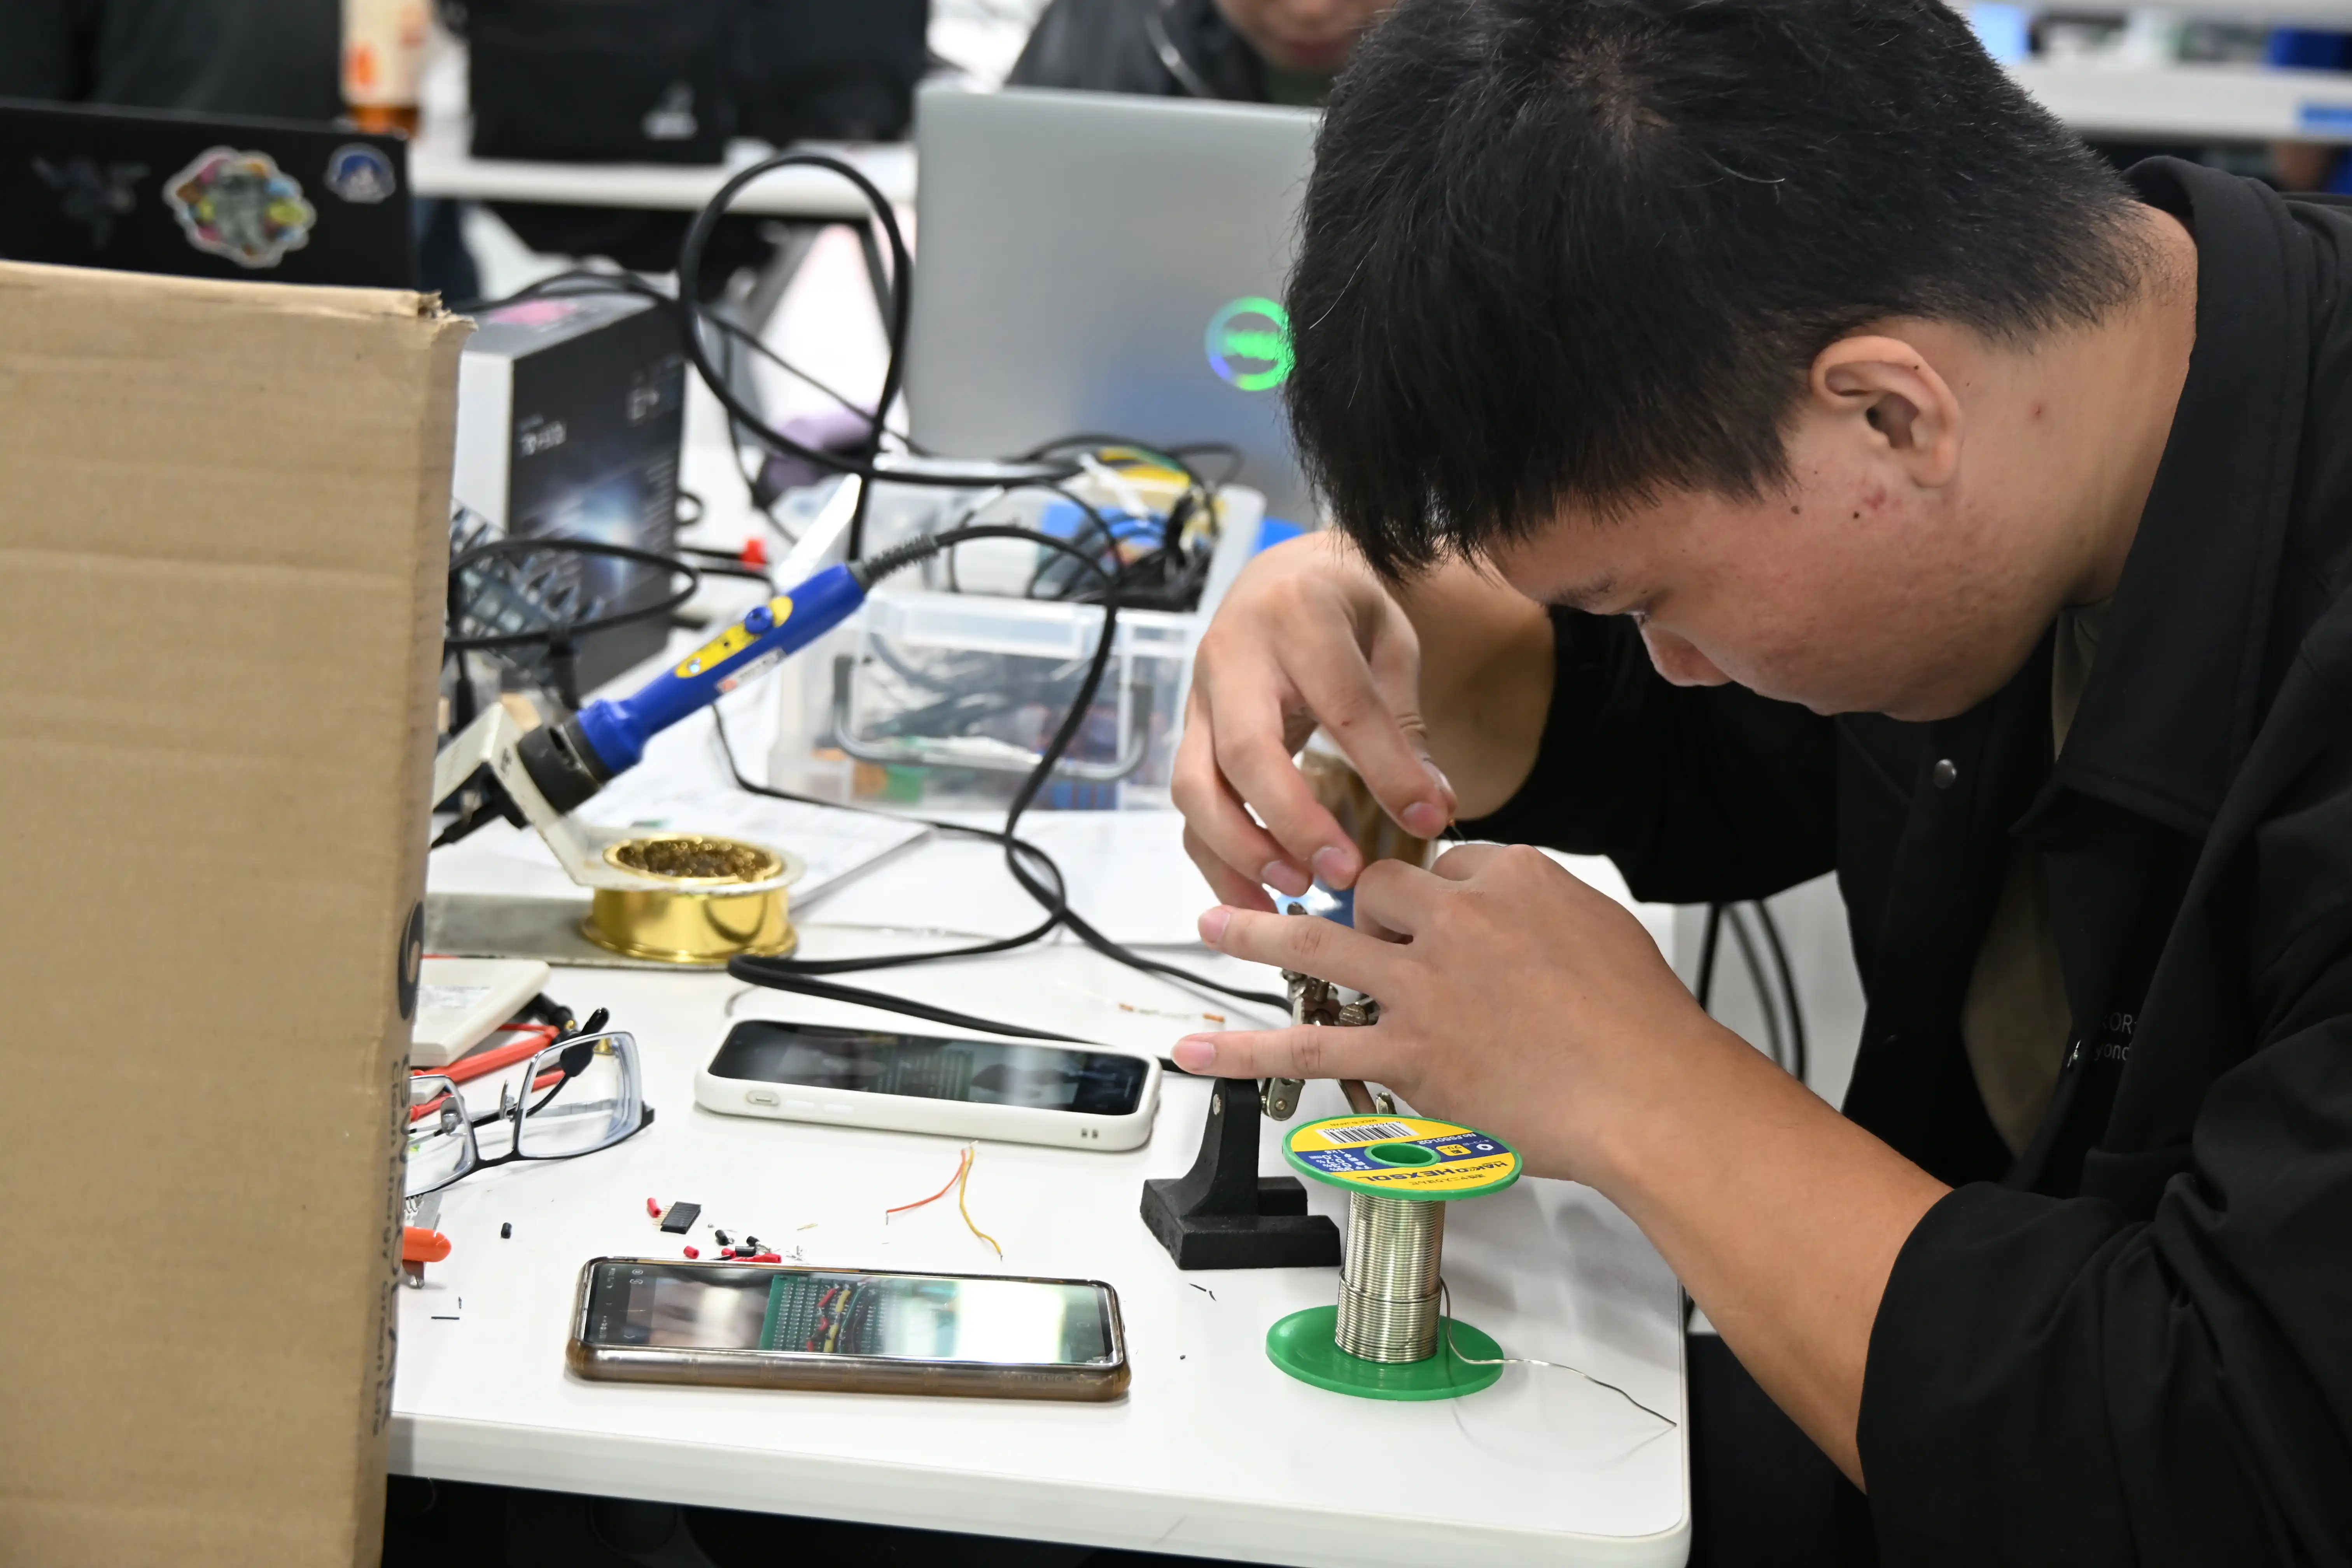
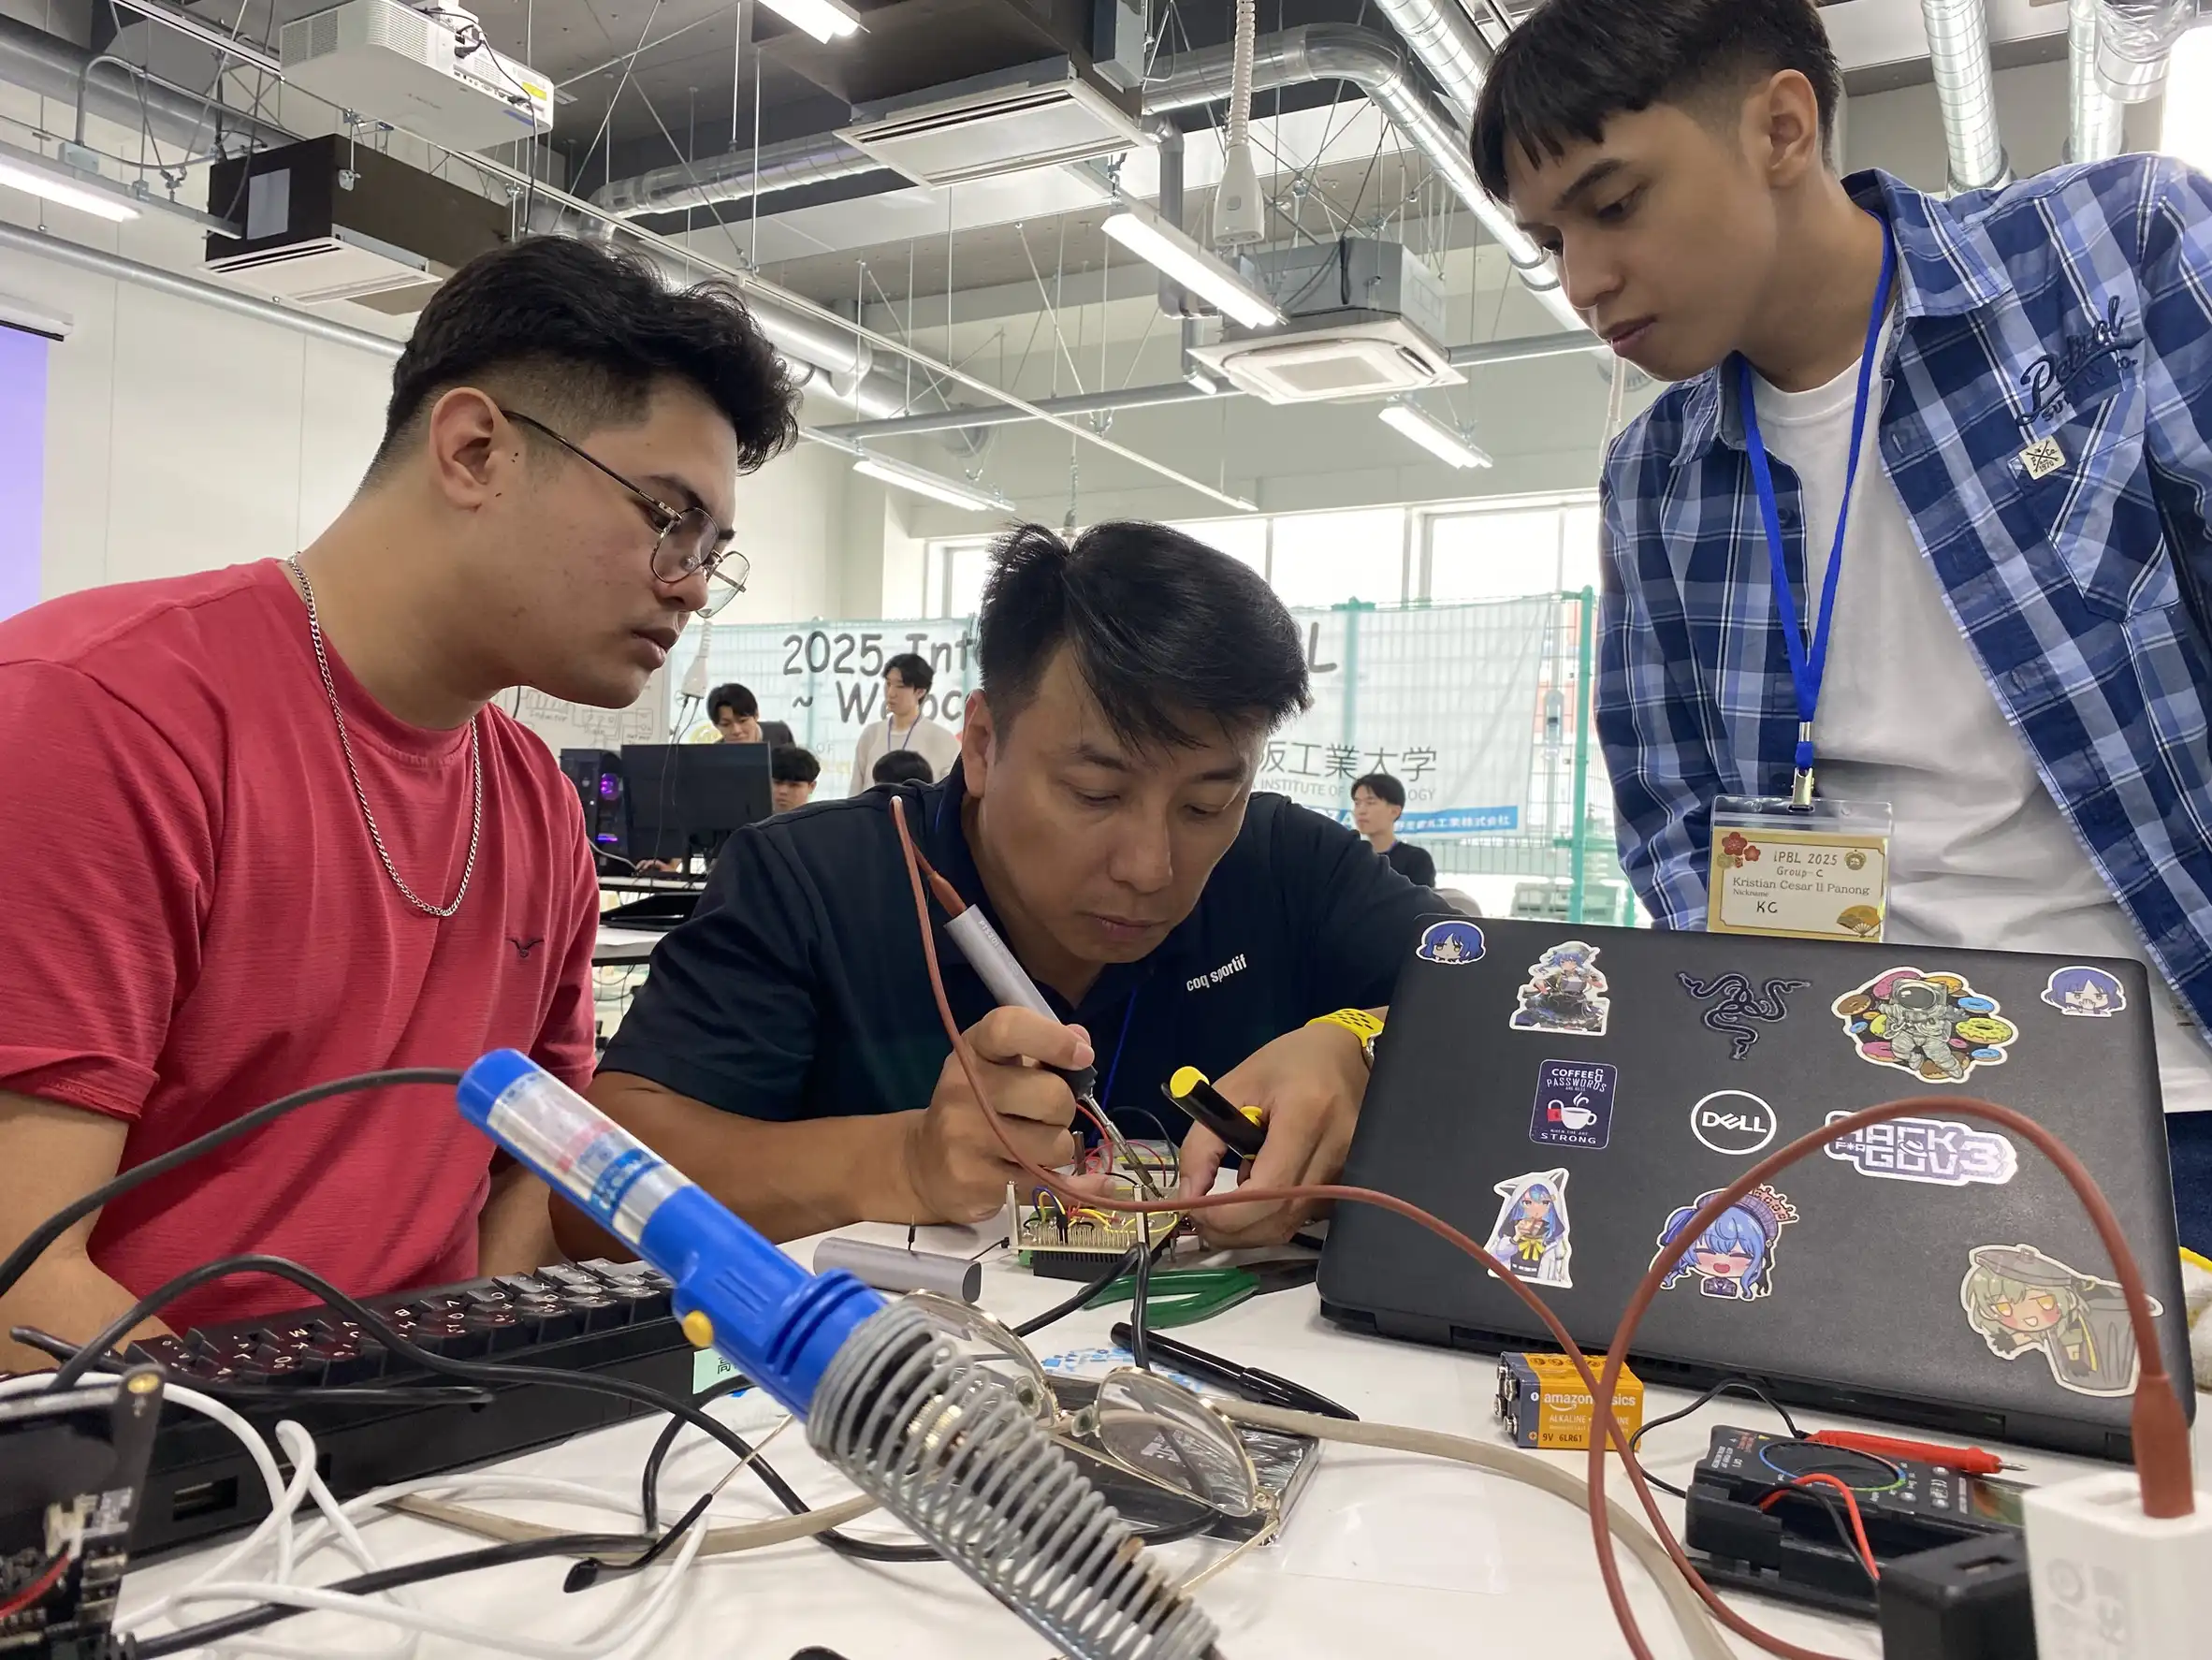
Delegates from the Philippines, Taiwan, and Japan converge in Cebu to build and program a spider-inspired, four-legged autonomous robot, fitted with a camera, an AI object-detection system, and a proximity sensor, geared toward search-and-rescue scenarios.
See the Programme ↓iPBL runs in two phases. Individual build work, completed at each delegate's home campus before travel, brought the quadruped to a working mechanical crawl. The intensive in-person phase, now underway with every delegation gathered in Cebu, extends that platform with computer vision and a proximity sensor, teaching the finished robot to see, sense its surroundings, and move toward autonomous behaviour.
Teams build and program a spider-inspired, four-legged autonomous robot fitted with a camera, an AI-based object-detection system, and a proximity sensor. Delegates assembled and calibrated the hardware individually before travel, then in Cebu add computer vision and proximity sensing, from locomotion control to vision-based target identification, with applications geared toward search-and-rescue scenarios.
iPBL 2026 draws delegates from three universities across the Philippines, Taiwan, and Japan.

iPBL 2026 is held on-site at the USJ-R Quadricentennial Campus, the university's newest campus building along Colon Street in downtown Cebu City.
The 2026 cohort's kits, PCBs, and shipping to partner delegates are made possible by the generous support of the following sponsors.

Every delegate arrives in Cebu having already built and calibrated their own quadruped. Start there.
Open the Quadruped Manual →